unitquaternion Class Reference
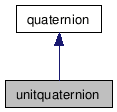
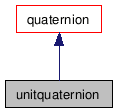
Detailed Description
A unit lenght quaternion class.The unitquaternion class manages quaternions of unit length, such quaternions can be used to represent arbitrary rotations. To mantain the unit lenght property along quaternion calculus addition and subtraction as well as multiplication and division by scalars are not allowed (they're made private or they're overloaded by "trap" functions).
Actually only a few member functions of the base class are overloaded since the quaternion calculus apply with no modification to unit quaternions.
Public Member Functions | |
| real | x () const |
| accessor for the x component of the vector part | |
| real | y () const |
| accessor for the y component of the vector part | |
| real | z () const |
| accessor for the z component of the vector part | |
| real | w () const |
| accessor for the scalar part | |
| real | scalarPart () const |
| other accessor for the scalar component | |
| vector | vectorPart () const |
| accessor for the vector part | |
| unitquaternion () | |
| default constructor | |
| unitquaternion (const real &angle, const vector &axis) | |
| constructs a unitquaternion representing a rotation of angle radiants about axis | |
| unitquaternion (const quaternion &q) | |
| constructs a unitquaternion from a generic one (conversion by normalizing) | |
| ~unitquaternion () | |
| the distructor | |
| unitquaternion | inversed () const |
| inversed copy of the unitquaternion | |
| void | inverse () |
| inverse of the unitquaternion | |
| tmatrix | getRotMatrix () |
| void | getVectorsOnSphere (vector &vfrom, vector &vto) |
| unitquaternion & | operator *= (const unitquaternion &other) |
| multiply by another unitquaternion & assign is not allowed | |
Private Member Functions | |
| unitquaternion & | operator+= (const unitquaternion &other) |
| sum & assign is not allowed | |
| unitquaternion & | operator-= (const unitquaternion &other) |
| subtract & assign is not allowed | |
| unitquaternion & | operator *= (const real &fact) |
| multiply by a scalar factor & assign is not allowed | |
| unitquaternion & | operator/= (const real &fact) |
| divide by a scalar factor & assign is not allowed | |
| unitquaternion (const vector &v, const real &s) | |
| constructs a unitquaternion assigning directly the scalar and vector parts | |
Friends | |
| unitquaternion | operator+ (const unitquaternion &q1, const unitquaternion &q2) |
| the sum is not allowed | |
| unitquaternion | operator- (const unitquaternion &q1, const unitquaternion &q2) |
| the difference is not allowed | |
| unitquaternion | operator * (const unitquaternion &q, const real &s) |
| multiply a unitquaternion by a scalar is not allowed | |
| unitquaternion | operator * (const real &s, const unitquaternion &q) |
| multiply a scalar by a unitquaternion is not allowed | |
| unitquaternion | operator/ (const unitquaternion &q, const real &s) |
| divide a unitquaternion by a scalar factor is not allowed | |
Constructor & Destructor Documentation
| unitquaternion | ( | const vector & | v, | |
| const real & | s | |||
| ) | [inline, private] |
constructs a unitquaternion assigning directly the scalar and vector parts
This constructor has been introduced exclusively to make the inversed function more efficient by avoiding too many unitquaternion copies and conversions to quaternions.
| unitquaternion | ( | ) | [inline] |
default constructor
| unitquaternion | ( | const real & | angle, | |
| const vector & | axis | |||
| ) | [inline] |
constructs a unitquaternion representing a rotation of angle radiants about axis
This constructor has a different meaning from the same in the base class. Here the vector means an axis of rotation while the real means the angle to rotate about the axis.
NOTE: the angle and axis vector are not directly assigned to the real part and the vector part, respectively, of the quaternion. The unit quaternion (s,v) represents a rotation of angle radians about the axis a if:
s = cos(angle / 2)
v = a * sin( angle / 2)
- Parameters:
-
angle the rotation angle axis the axis of rotation
- Date:
- 18/06/99
| unitquaternion | ( | const quaternion & | q | ) | [inline] |
constructs a unitquaternion from a generic one (conversion by normalizing)
| ~unitquaternion | ( | ) | [inline] |
the distructor
Member Function Documentation
| unitquaternion& operator+= | ( | const unitquaternion & | other | ) | [private] |
sum & assign is not allowed
| unitquaternion& operator-= | ( | const unitquaternion & | other | ) | [private] |
subtract & assign is not allowed
| unitquaternion& operator *= | ( | const real & | fact | ) | [private] |
| unitquaternion& operator/= | ( | const real & | fact | ) | [private] |
| real x | ( | ) | const [inline] |
| real y | ( | ) | const [inline] |
| real z | ( | ) | const [inline] |
| real w | ( | ) | const [inline] |
accessor for the scalar part
This function overrides the same in base class to prevent the use as an l-value (that is to modify the scalar part).
| real scalarPart | ( | ) | const [inline] |
other accessor for the scalar component
This function overrides the same in base class to prevent the use as an l-value (that is to modify the scalar part).
| vector vectorPart | ( | ) | const [inline] |
| unitquaternion inversed | ( | ) | const [inline] |
inversed copy of the unitquaternion
For unitquaternions the inverse equals the conjugate (which is simpler to calculate) This function doesn't modifies the quaternion upon which has been called, it returns a new quaternion instead.
- Returns:
- the normalized copy of the quaternion
- Date:
- 18/06/99
Reimplemented from quaternion.
| void inverse | ( | ) | [inline] |
inverse of the unitquaternion
For unitquaternions the inverse equals the conjugate (which is simpler to calculate). The function doesn't call the base conjugate function to avoid an expensive quaternion to unitquaternion conversion. This function modifies the quaternion upon which has been called.
Reimplemented from quaternion.
| tmatrix getRotMatrix | ( | ) | [virtual] |
The generated rotation matrix is OpenGL compatible, it is intended to be post-multiplied to the current trasformation matrix to achieve the rotation.
- Returns:
- the rotation matrix
Reimplemented from quaternion.
the rotation represented by the unitquaternion would transform the first vector into the second. The vectors are of unit length (so they are placed on a unit sphere)
| unitquaternion & operator *= | ( | const unitquaternion & | other | ) |
multiply by another unitquaternion & assign is not allowed
Friends And Related Function Documentation
| unitquaternion operator+ | ( | const unitquaternion & | q1, | |
| const unitquaternion & | q2 | |||
| ) | [friend] |
the sum is not allowed
This function has been defined to trap the use of an operation which is not allowed
| unitquaternion operator- | ( | const unitquaternion & | q1, | |
| const unitquaternion & | q2 | |||
| ) | [friend] |
the difference is not allowed
This function has been defined to trap the use of an operation which is not allowed
| unitquaternion operator * | ( | const unitquaternion & | q, | |
| const real & | s | |||
| ) | [friend] |
multiply a unitquaternion by a scalar is not allowed
This function has been defined to trap the use of an operation which is not allowed
| unitquaternion operator * | ( | const real & | s, | |
| const unitquaternion & | q | |||
| ) | [friend] |
multiply a scalar by a unitquaternion is not allowed
This function has been defined to trap the use of an operation which is not allowed
| unitquaternion operator/ | ( | const unitquaternion & | q, | |
| const real & | s | |||
| ) | [friend] |
divide a unitquaternion by a scalar factor is not allowed
This function has been defined to trap the use of an operation which is not allowed