quaternion Class Reference
Detailed Description
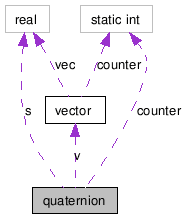
A generic quaternion class. The quaternion uses internally the (s,v) representation, where s is a scalar and v a vector. The most common operations from quaternion calculus are implemented.Some internet references are:
- http://www.cs.berkley.edu/~laura/cs184/quat/quaternion.html
- http://www.astro.virginia.edu/~eww6n/math/Quaternion.html
- http://forum.swarthmore.edu/dr.math/problems/prasad2.17.96.html
- http://graphics.cs.ucdavis.edu/GraphicsNotes/Quaternions/Quaternions.html
A paper by Ken Shoemake (the quaternions "inventor") is available at
Public Member Functions | |
| quaternion () | |
| default constructor | |
| quaternion (const real &scal, const vector &vec) | |
| constructs a quaternion from the scalar and vector components | |
| quaternion (const real &s1, const real &s2, const real &s3, const real &s4) | |
| constructs a quaternion from four real values | |
| quaternion (const quaternion &other) | |
| the copy constructor | |
| virtual | ~quaternion () |
| the distructor | |
| real & | x () |
| accessor for the x component of the vector part (can be used as l-value too) | |
| real & | y () |
| accessor for the y component of the vector part (can be used as l-value too) | |
| real & | z () |
| accessor for the z component of the vector part (can be used as l-value too) | |
| real & | w () |
| accessor for the scalar part (can be used as l-value too) | |
| real & | scalarPart () |
| other accessor for the scalar component (can be used as l-value too) | |
| vector & | vectorPart () |
| accessor for the vector part (can be used as l-value too) | |
| quaternion & | operator= (const quaternion &other) |
| assignment | |
| quaternion & | operator+= (const quaternion &other) |
| sum & assign | |
| quaternion & | operator-= (const quaternion &other) |
| subtract & assign | |
| quaternion & | operator *= (const quaternion &other) |
| multiply by a quaternion & assign | |
| quaternion & | operator/= (const quaternion &other) |
| divide by a quaternion & assign | |
| quaternion & | operator *= (const real &fact) |
| multiply by a scalar factor & assign | |
| quaternion & | operator/= (const real &fact) |
| divide by a scalar factor & assign | |
| real | normalize () |
| normalize the quaternion | |
| quaternion | normalized () const |
| normalized copy of the quaternion | |
| void | conjugate () |
| conjugate of the quaternion | |
| quaternion | conjugated () const |
| conjugated copy of the quaternion | |
| real | inverse () |
| inverse of the quaternion | |
| quaternion | inversed () const |
| inversed copy of the quaternion | |
| real | length () const |
| get the length of the quaternion | |
| real | norm () const |
| get the norm (similar to the squared length) of the quaternion | |
| virtual tmatrix | getRotMatrix () |
Static Public Member Functions | |
| static int | howMany () |
| returns how many quaternion objects exists | |
Protected Attributes | |
| real | s |
| the scalar part of a quaternion | |
| vector | v |
| the vector part of a quaternion | |
Static Private Attributes | |
| static int | counter = 0 |
| counts how many quaternion objects are present | |
Friends | |
| int | operator== (const quaternion &q1, const quaternion &q2) |
| the equality operator | |
| int | operator!= (const quaternion &q1, const quaternion &q2) |
| the inequality operator | |
| quaternion | operator+ (const quaternion &q1, const quaternion &q2) |
| the sum | |
| quaternion | operator- (const quaternion &q1, const quaternion &q2) |
| the difference | |
| quaternion | operator- (const quaternion &q1) |
| negation | |
| quaternion | operator * (const quaternion &q1, const quaternion &q2) |
| quaternion product | |
| quaternion | operator * (const quaternion &q, const real &s) |
| multiply a quaternion by a scalar | |
| quaternion | operator * (const real &s, const quaternion &q) |
| multiply a scalar by a quaternion | |
| quaternion | operator/ (const quaternion &q, const real &s) |
| divide a quaternion by a scalar factor | |
| quaternion | operator/ (const quaternion &q1, const quaternion &q2) |
| divide a quaternion by a quaternion | |
| ostream & | operator<< (ostream &os, const quaternion &q) |
| print quaternion to C++ stream | |
Constructor & Destructor Documentation
| quaternion | ( | ) | [inline] |
default constructor
| quaternion | ( | const real & | scal, | |
| const vector & | vec | |||
| ) | [inline] |
constructs a quaternion from the scalar and vector components
| quaternion | ( | const real & | s1, | |
| const real & | s2, | |||
| const real & | s3, | |||
| const real & | s4 | |||
| ) | [inline] |
constructs a quaternion from four real values
This constructor assumes an (s,v) form so interprets the real calues as w,x,y,z respectively. Another common representation for quaternions, the "homogeneous" one, is x,y,x,w ordered.
- Parameters:
-
s1 the scalar part s2 the x component of the vector part s3 the y component of the vector part s4 the z component of the vector part
- Date:
- 15/06/99
| quaternion | ( | const quaternion & | other | ) | [inline] |
the copy constructor
| ~quaternion | ( | ) | [inline, virtual] |
the distructor
Member Function Documentation
| real & w | ( | ) | [inline] |
accessor for the scalar part (can be used as l-value too)
| real & scalarPart | ( | ) | [inline] |
other accessor for the scalar component (can be used as l-value too)
| quaternion & operator= | ( | const quaternion & | other | ) | [inline] |
assignment
| quaternion & operator+= | ( | const quaternion & | other | ) | [inline] |
sum & assign
| quaternion & operator-= | ( | const quaternion & | other | ) | [inline] |
subtract & assign
| quaternion & operator *= | ( | const quaternion & | other | ) |
multiply by a quaternion & assign
| quaternion & operator/= | ( | const quaternion & | other | ) |
divide by a quaternion & assign
| quaternion & operator *= | ( | const real & | fact | ) | [inline] |
| quaternion & operator/= | ( | const real & | fact | ) | [inline] |
| real normalize | ( | ) |
normalize the quaternion
This function modifies the quaternion upon which has been called.
- Returns:
- the length of the quaternion before normalization, this is useful to check if the normalization operation has been numerically precise.
| quaternion normalized | ( | ) | const |
normalized copy of the quaternion
This function doesn't modifies the quaternion upon which has been called, it returns a new quaternion instead.
- Returns:
- the normalized copy of the quaternion
| void conjugate | ( | ) | [inline] |
conjugate of the quaternion
| quaternion conjugated | ( | ) | const [inline] |
conjugated copy of the quaternion
| real inverse | ( | ) |
inverse of the quaternion
This function modifies the quaternion upon which has been called.
- Returns:
- the norm of the quaternion before the internal normalization, this is useful to check if the normalization operation has been numerically precise.
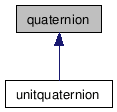
Reimplemented in unitquaternion.
| quaternion inversed | ( | ) | const |
inversed copy of the quaternion
This function doesn't modifies the quaternion upon which has been called, it returns a new quaternion instead.
Reimplemented in unitquaternion.
| real length | ( | ) | const [inline] |
get the length of the quaternion
| real norm | ( | ) | const |
get the norm (similar to the squared length) of the quaternion
NOTE: the norm is comparable to the squared length of a vector not to the length
| tmatrix getRotMatrix | ( | ) | [virtual] |
Generates a rotation matrix even from non unit quaternions (only for unit quaternoin the result is the same as unitquaternion::getRotMatrix). The generated rotation matrix is OpenGL compatible, it is intended to be post-multiplied to the current trasformation matrix to achieve the rotation.
- Returns:
- the rotation matrix
Reimplemented in unitquaternion.
| int howMany | ( | ) | [inline, static] |
returns how many quaternion objects exists
The counting of the quaternion objects is realized trough a static counter variable.
- Returns:
- the number of quaternion objects in memory
Friends And Related Function Documentation
| int operator== | ( | const quaternion & | q1, | |
| const quaternion & | q2 | |||
| ) | [friend] |
the equality operator
This function check if two quaternions are equal.
| int operator!= | ( | const quaternion & | q1, | |
| const quaternion & | q2 | |||
| ) | [friend] |
the inequality operator
This function check if two quaternions are not equal.
| quaternion operator+ | ( | const quaternion & | q1, | |
| const quaternion & | q2 | |||
| ) | [friend] |
the sum
| quaternion operator- | ( | const quaternion & | q1, | |
| const quaternion & | q2 | |||
| ) | [friend] |
the difference
| quaternion operator- | ( | const quaternion & | q1 | ) | [friend] |
negation
| quaternion operator * | ( | const quaternion & | q1, | |
| const quaternion & | q2 | |||
| ) | [friend] |
quaternion product
| quaternion operator * | ( | const quaternion & | q, | |
| const real & | s | |||
| ) | [friend] |
multiply a quaternion by a scalar
This function together with operator*(real,quaternion) implements the commutative product of a scalar by a quaternion
| quaternion operator * | ( | const real & | s, | |
| const quaternion & | q | |||
| ) | [friend] |
multiply a scalar by a quaternion
This function together with operator*(quaternion,real) implements the commutative product of a scalar by a quaternion
| quaternion operator/ | ( | const quaternion & | q, | |
| const real & | s | |||
| ) | [friend] |
divide a quaternion by a scalar factor
| quaternion operator/ | ( | const quaternion & | q1, | |
| const quaternion & | q2 | |||
| ) | [friend] |
divide a quaternion by a quaternion
| ostream& operator<< | ( | ostream & | os, | |
| const quaternion & | q | |||
| ) | [friend] |
print quaternion to C++ stream
Member Data Documentation
int counter = 0 [static, private] |
counts how many quaternion objects are present
the scalar part of a quaternion
the vector part of a quaternion